The same robot turns up in different configurations, so the dex groups sightings by family, then by variant: a variant is told apart by its signature — whether an arm is fitted, what sits on top, and how it moves. A sighting that matches no variant starts a new one; a robot that matches no family starts a new family.
An existing design by its original makers — the Robodex records Andino with provenance: License is per-package LICENSE files in the repo (each reads BSD 3-Clause, (c) 2023 Ekumen Inc.); the repo root carries no single LICENSE file. Spec values were read from andino_description/config/andino/*.yaml and the andino_hardware BOM. (license: BSD-3-Clause)
Andino + top lidar (rplidar_a1) + ultrasonic_sensor
No arm · rplidar_a1 on top · differential drive · payloads: ultrasonic_sensor
Andino
Boston Dynamics Spot
Not identified against the Robodex. Its public footprint starts at bostonrb/bostonrb (owner bostonrb); credit belongs to that project's authors, whoever they are.
Boston Dynamics Spot with Arm
Arm fitted · no top lidar · skid steer drive
Boston Dynamics Spot — spotted 2026-10-28 · Cal Poly Pomona IRLab
Saved in this browser
Sightings you add are stored only in this browser in v1; the shared dex sync is the live endpoint’s job once deployed.
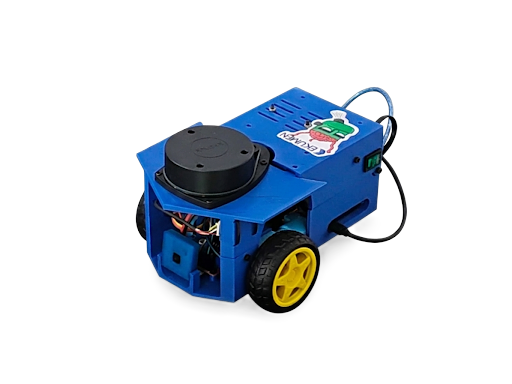
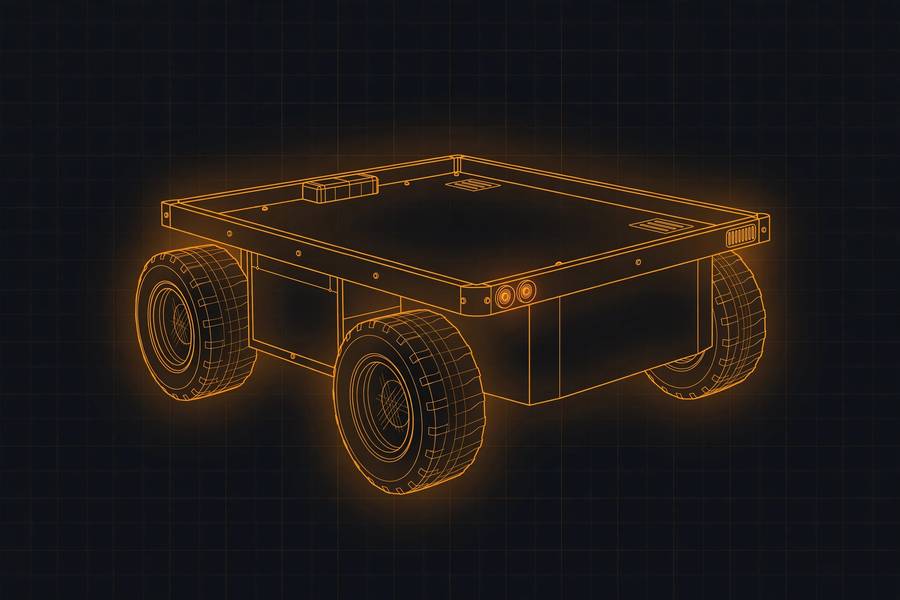




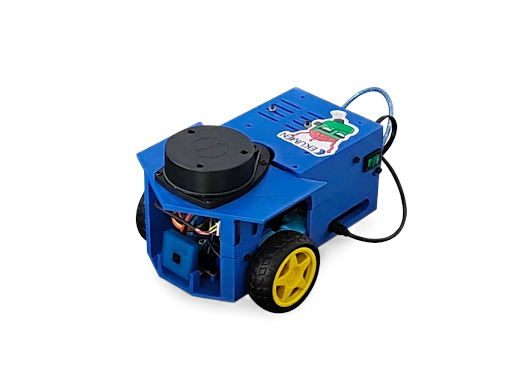 Andino
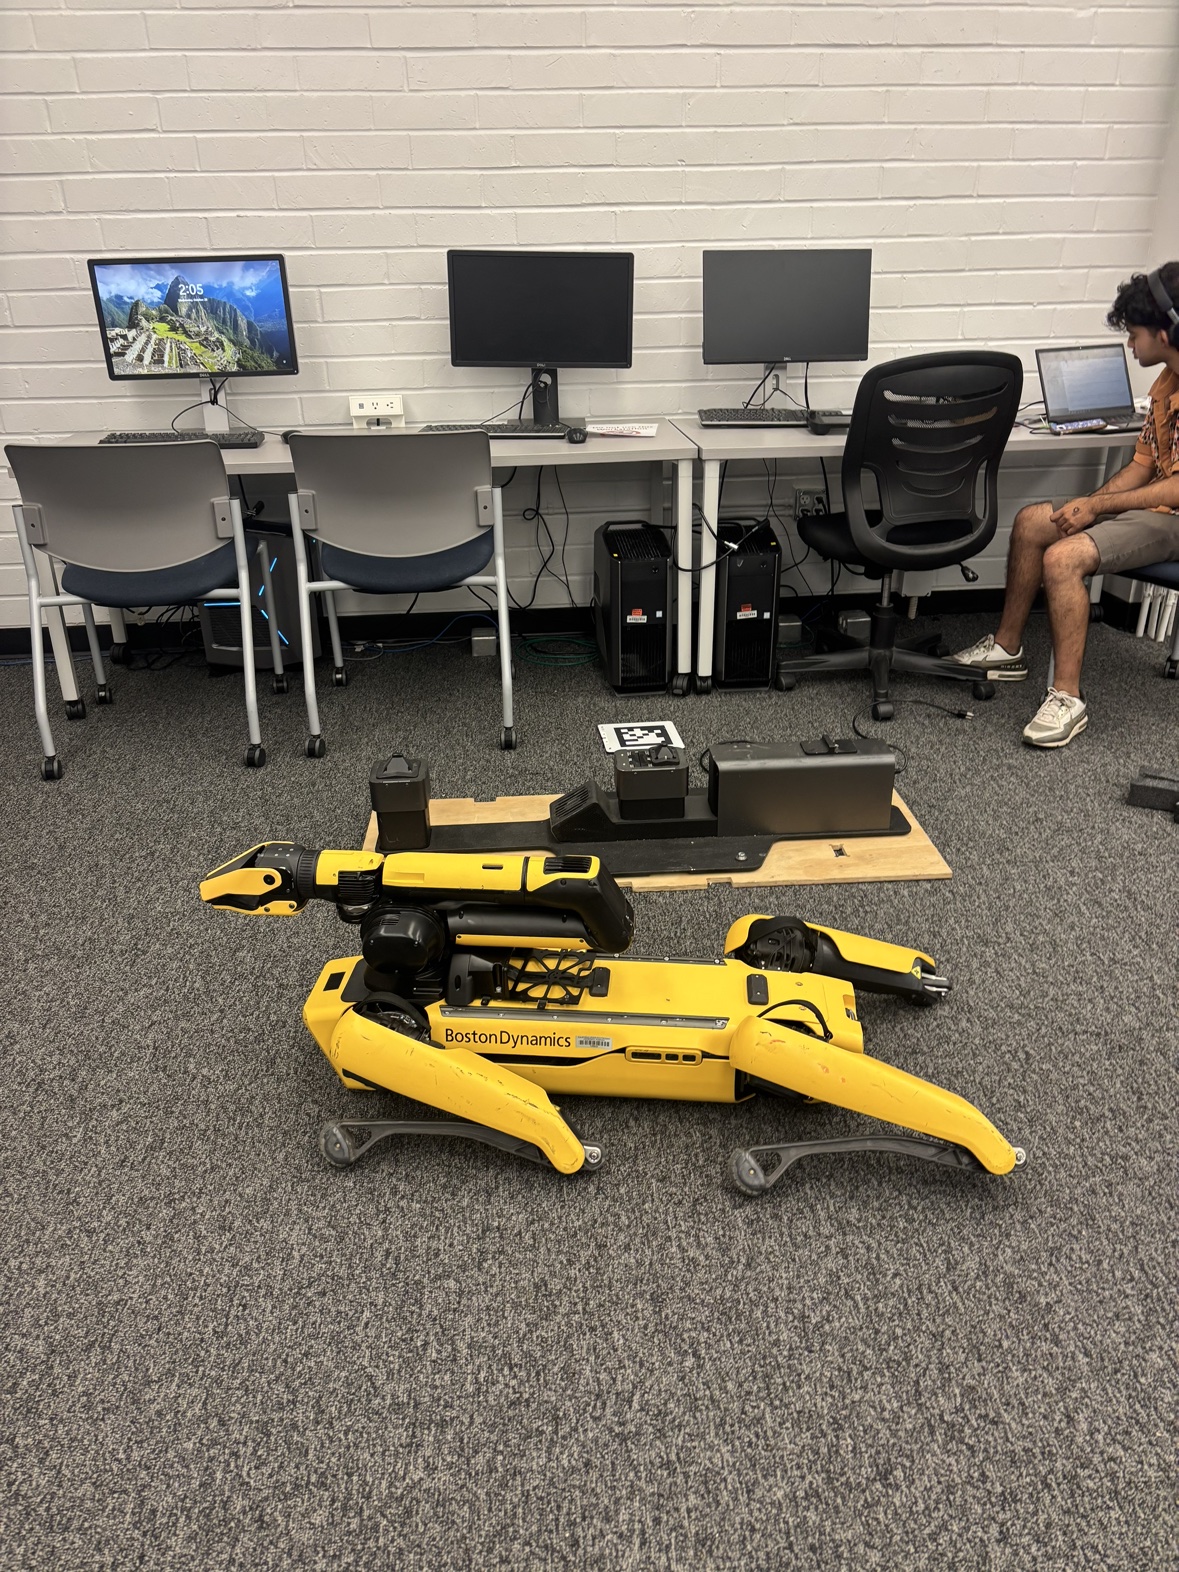 Boston Dynamics Spot