The Parts Kit, in 3D
A forged robot is a kit of parts, not a monolith. Drag to orbit, pinch or scroll to zoom, tap any part to inspect it — then pull the explode slider and watch it come apart. Flip on CAD mode and the same model becomes parametric OpenSCAD you can download, open in OpenSCAD or FreeCAD, edit, and print. Geometry: TurtleBot3 Burger dims — the robot the gate passed.
Click a part in 3D to inspect the real catalogue part behind it.
CAD — OpenSCAD
Generated live from the same parameters as the 3D model, explode included. Select a part to get its module alone, or download the whole assembly.
// RobotForge take-apart kit - TurtleBot3 Burger (parametric, mm)
// Generated from the same parameters as the 3D viewer on robotforge's parts page.
// Set explode = 0 for the assembled robot, 1 for the fully exploded kit.
explode = 0.00;
$fn = 32;

// Chassis plates — two 178 x 138 mm plates (Burger footprint)
module chassis_plate(){ cube([178,138,10], center=true); }
module chassis(){ translate([0,0,75 + 8*explode]) chassis_plate(); translate([0,0,145 + 24*explode]) chassis_plate(); }

// Battery pack — 3S 2200 mAh class pack between the plates
module battery(){ translate([0,0,105 - 88*explode]) cube([95,60,35], center=true); }

// Onboard computer — Pi-class board on the top plate
module sbc(){ translate([-20,0,155 + 88*explode]) cube([85,56,6], center=true); }

// Motor driver — TB6612FNG-class dual H-bridge board
module driver(){ translate([45 + 50*explode,0,153 + 56*explode]) cube([45,45,5], center=true); }

// 2D lidar — RPLIDAR-class turret, 70 mm diameter
module lidar(){ translate([45,0,192 + 160*explode]) cylinder(h=34, d=70, center=true, $fn=48); }

// Gear motors x2 — inboard of the driven wheels
module motors(){ for (s=[1,-1]) translate([0, s*(62 + 28*explode), 36]) rotate([90,0,0]) cylinder(h=32, d=26, center=true, $fn=32); }

// Driven wheels x2 — 66 mm dia x 21 mm (the dimension the gate grades)
module wheels(){ for (s=[1,-1]) translate([0, s*(80 + 55*explode), 36]) rotate([90,0,0]) cylinder(h=21, d=66, center=true, $fn=48); }

// Caster balls x2 — passive supports, 33 mm spheres
module caster(){ for (s=[1,-1]) translate([s*(62 + 30*explode), 0, 16.5 - 60*explode]) sphere(d=33, $fn=32); }

// Assembly
chassis();
battery();
sbc();
driver();
lidar();
motors();
wheels();
caster();
Parts catalogue
50 real parts with datasheet-sourced specs, grouped by class. These are what the forge assembles robots from and checks parts lists against.
actuators (6)
Brushed motor 540 size
The standard 540-size brushed motor from RC cars.
Brushless motor 2207 1960 KV
An FPV quad motor: small, light, spins very fast.
DC gearmotor 12 V (37 mm class)
A DC motor with a built-in gearbox: slow, strong turning for wheels.
MG996R servo
A metal-gear hobby servo that turns to a commanded angle.
STS3215 serial bus servo (Feetech)
A serial-bus servo: many chain on one wire and report their position back.
Stepper motor NEMA 17
A stepper motor that moves in precise 1.8-degree steps.
cables & connectors (2)
Silicone wire 14 AWG (per metre)
Flexible silicone-insulated wire thick enough for battery current.
XT60 pigtail lead
A short lead with the yellow XT60 battery connector already soldered on.
cameras & sensors (5)
BNO055 9-DOF IMU breakout
A 9-axis motion sensor with on-chip orientation fusion (compass + gyro + accelerometer).
HC-SR04 ultrasonic ranger
The two-eyed sonar module: pings and times the echo to measure distance.
Intel RealSense D435 depth camera
A stereo depth camera: sees colour plus distance per pixel.
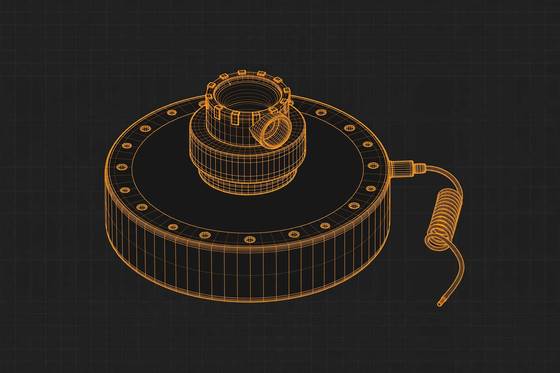
RPLIDAR A1 2D lidar
A spinning 2D laser scanner — it sweeps a room and reports distances all around.
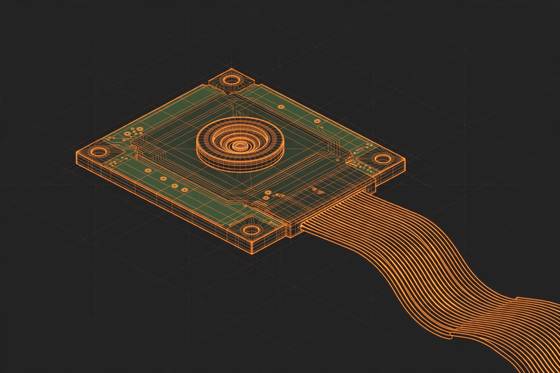
Raspberry Pi Camera Module V2 (8 MP)
The little ribbon-cable camera made for the Raspberry Pi.
comms (2)
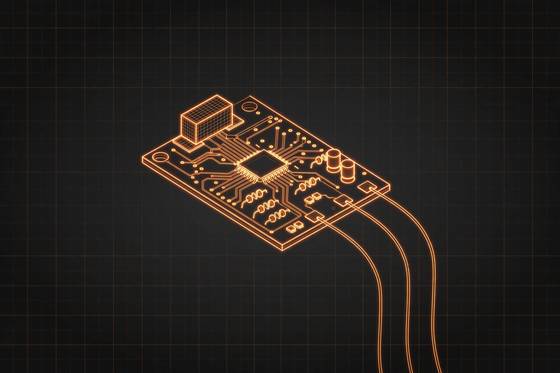
ExpressLRS receiver
A tiny ExpressLRS radio-control receiver.
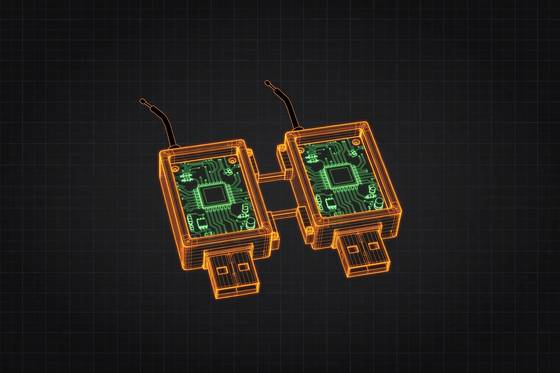
SiK telemetry radio pair (915 MHz)
A pair of long-range radio modems that make a wireless serial link.
custom boards (1)
Custom PCB (KiCad import)
Your own circuit board, designed in KiCad and fabricated to order.
drivers (4)
4-in-1 ESC 45 A (BLHeli_S class)
Four brushless speed controllers on one board for a quadcopter.
Brushed ESC 60 A (QuicRun 1060 class)
A single brushed speed controller for an RC car's main motor.
L298N dual motor driver module
The classic red dual H-bridge module for two DC motors or one stepper.
TB6612FNG dual motor driver
A small dual motor driver: runs two DC motors forward, reverse and brake from logic signals.
end effectors (1)
2-finger parallel gripper kit
A two-finger parallel gripper kit (servo not included).
flight control (1)
Flight controller stack F405
Flight-controller board stack that stabilises a quadcopter.
materials (2)
PETG filament 1.75 mm, 1 kg
A tougher, slightly flexible printing filament.
PLA filament 1.75 mm, 1 kg
The standard easy-print 3D printing plastic, on a 1 kg spool.
memory & storage (1)
microSD card 128 GB (A2/V30)
The removable flash card a Raspberry Pi boots from.
microcontrollers (3)
ESP32 development board
A Wi-Fi/Bluetooth microcontroller board — the robot's reflexes.
Raspberry Pi Pico (RP2040)
Raspberry Pi's cheap dual-core microcontroller board.
Teensy 4.1
A very fast microcontroller board popular for precise motion control.
power (6)
18650 Li-ion pack 3S (3 cells)
Three cylindrical 18650 cells in series — 11.1 V of robot power.
Buck converter 5 V / 5 A
Steps a higher battery voltage down to a clean 5 V.
LiPo balance charger
Charger that keeps every cell in a LiPo pack at the same voltage.
LiPo battery 3S 2200 mAh
A 3-cell LiPo pack, 11.1 V — the classic small-robot battery.
LiPo battery 4S 1500 mAh (5-inch quad)
A smaller 4-cell LiPo pack sized for a 5-inch quadcopter.
LiPo battery 4S 5200 mAh
A rechargeable lithium-polymer battery pack: 4 cells in series, 14.8 V, lots of capacity.
air propulsion (1)
Propeller 5x4.0x3 tri-blade
A 5-inch tri-blade propeller for FPV quads.
safety & protection (3)
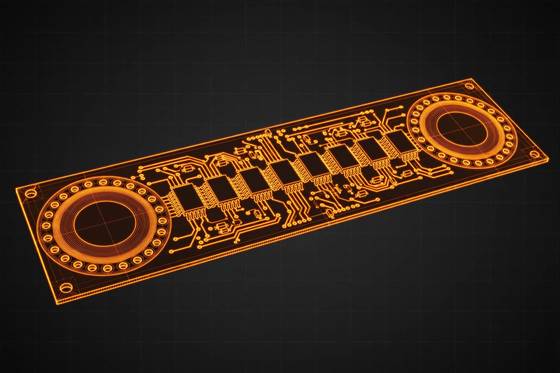
BMS protection board 4S 40 A
A battery-management board that protects a 4-cell pack from over/under-voltage.
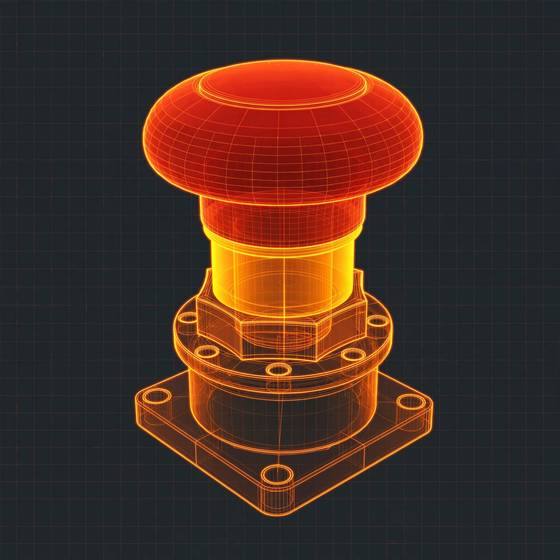
Emergency stop button (latching)
A big latching red button that cuts power when slapped.
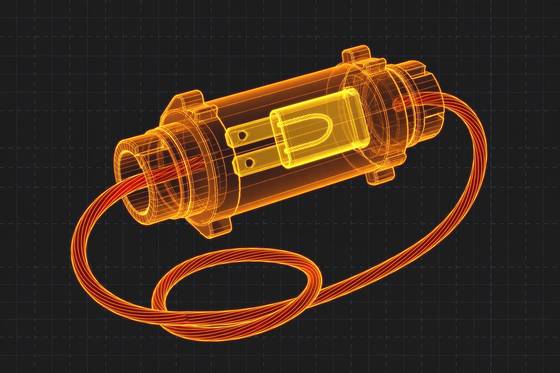
Inline blade fuse holder + fuse
A fuse holder wired into the battery's main lead.
single-board computers (2)
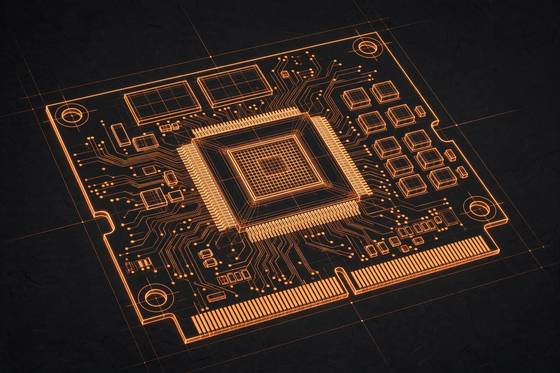
NVIDIA Jetson Orin Nano
A GPU computer module for robots that see: camera AI on a board the size of a laptop memory stick.
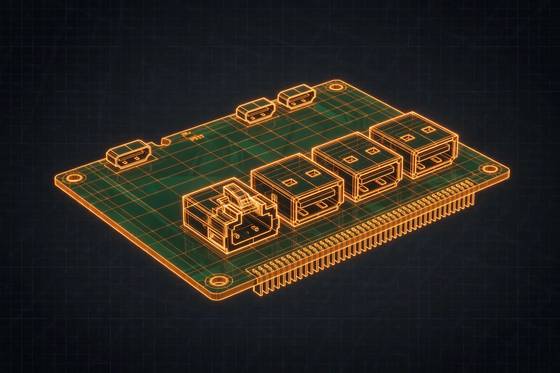
Raspberry Pi 5
A full Linux computer the size of a credit card.
structure (7)
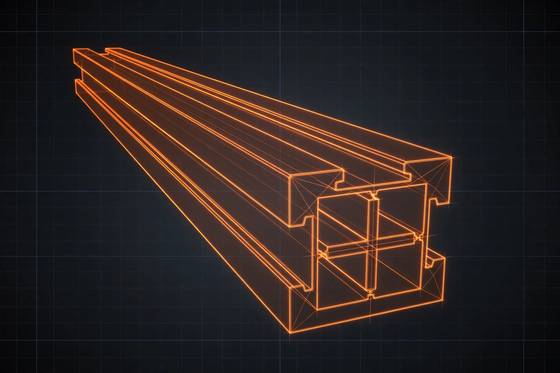
Aluminium extrusion 2020 (per metre)
Slotted aluminium profile, 20 by 20 mm, sold by the metre.
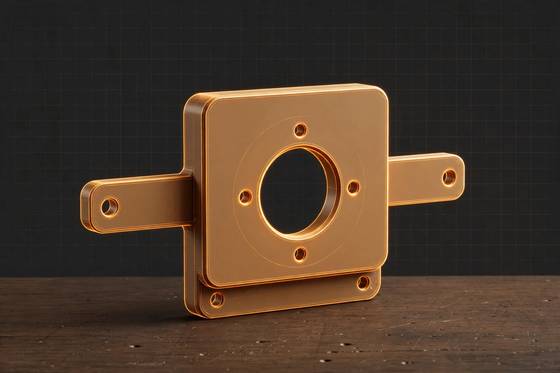
Camera bracket (3D-printed)
A small flat bracket that holds a camera facing forward.
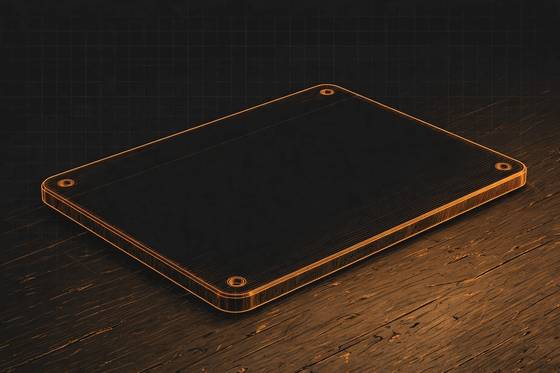
Chassis plate (3D-printed)
The flat deck everything bolts onto — in RobotForge it is generated for your robot, ready to print.
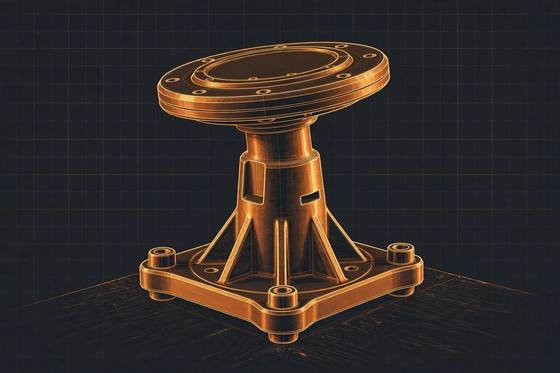
Lidar mount post (3D-printed)
A post that raises the 2D lidar above the deck for a clear 360-degree view.
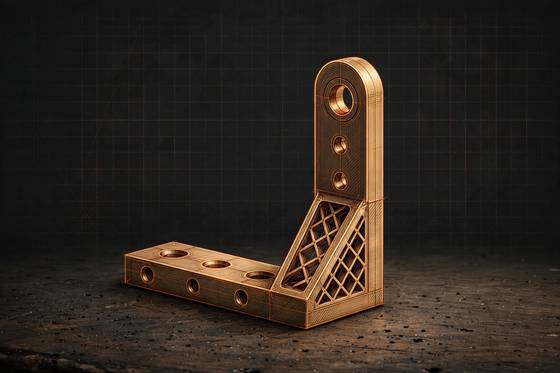
Motor mount bracket (3D-printed)
A small bracket that holds a gearmotor at exactly axle height.
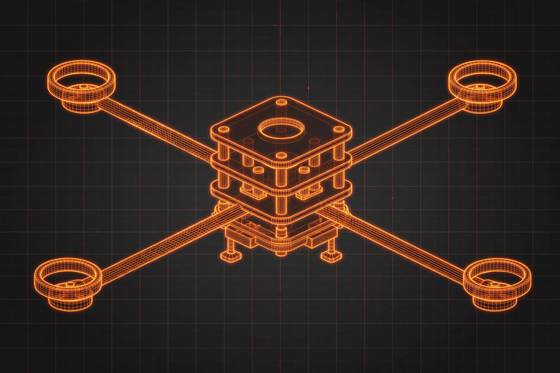
Quadcopter frame 5 inch (carbon)
A carbon-fibre frame sized for 5-inch propellers.
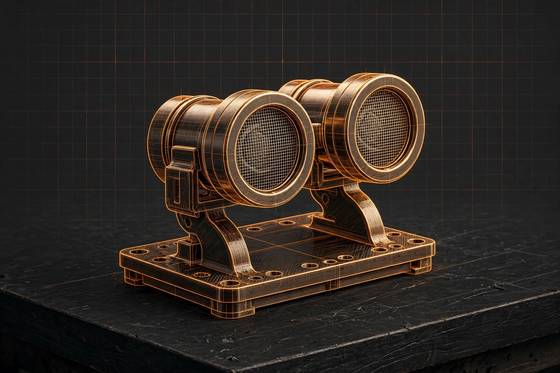
Ultrasonic bracket (3D-printed)
A twin-can bracket sized for an HC-SR04-style ultrasonic ranger.
wheels (3)
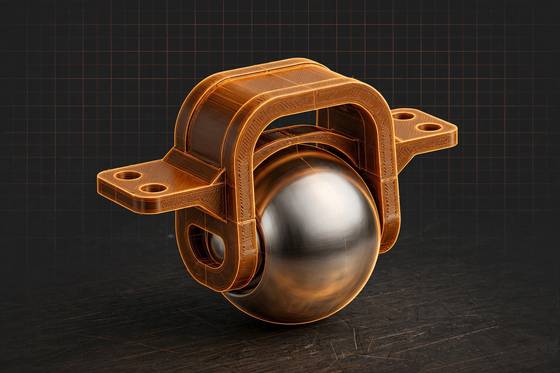
Ball caster
A free-rolling ball that supports the end of a two-wheel robot without steering it.
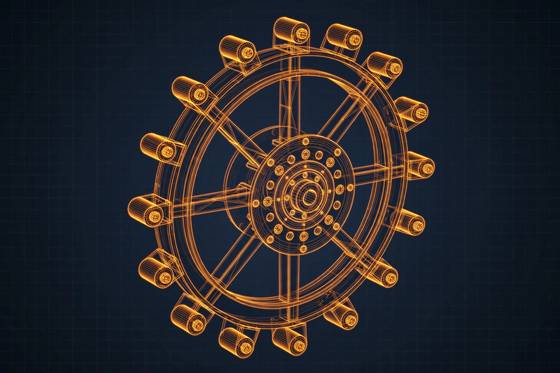
Mecanum wheel 100 mm
A wheel with angled rollers that lets a robot slide sideways.
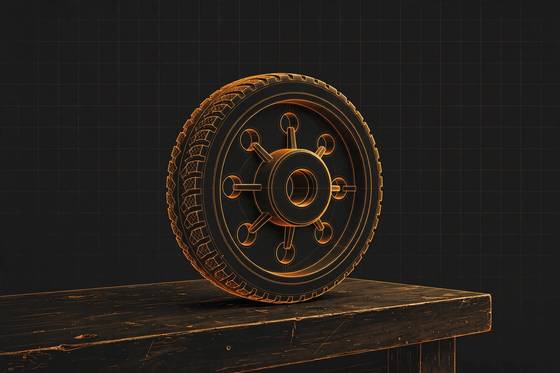
Wheel 100 mm diameter
A 100 mm robot wheel — the size on the Pathfinder spec.
No parts match that search.